
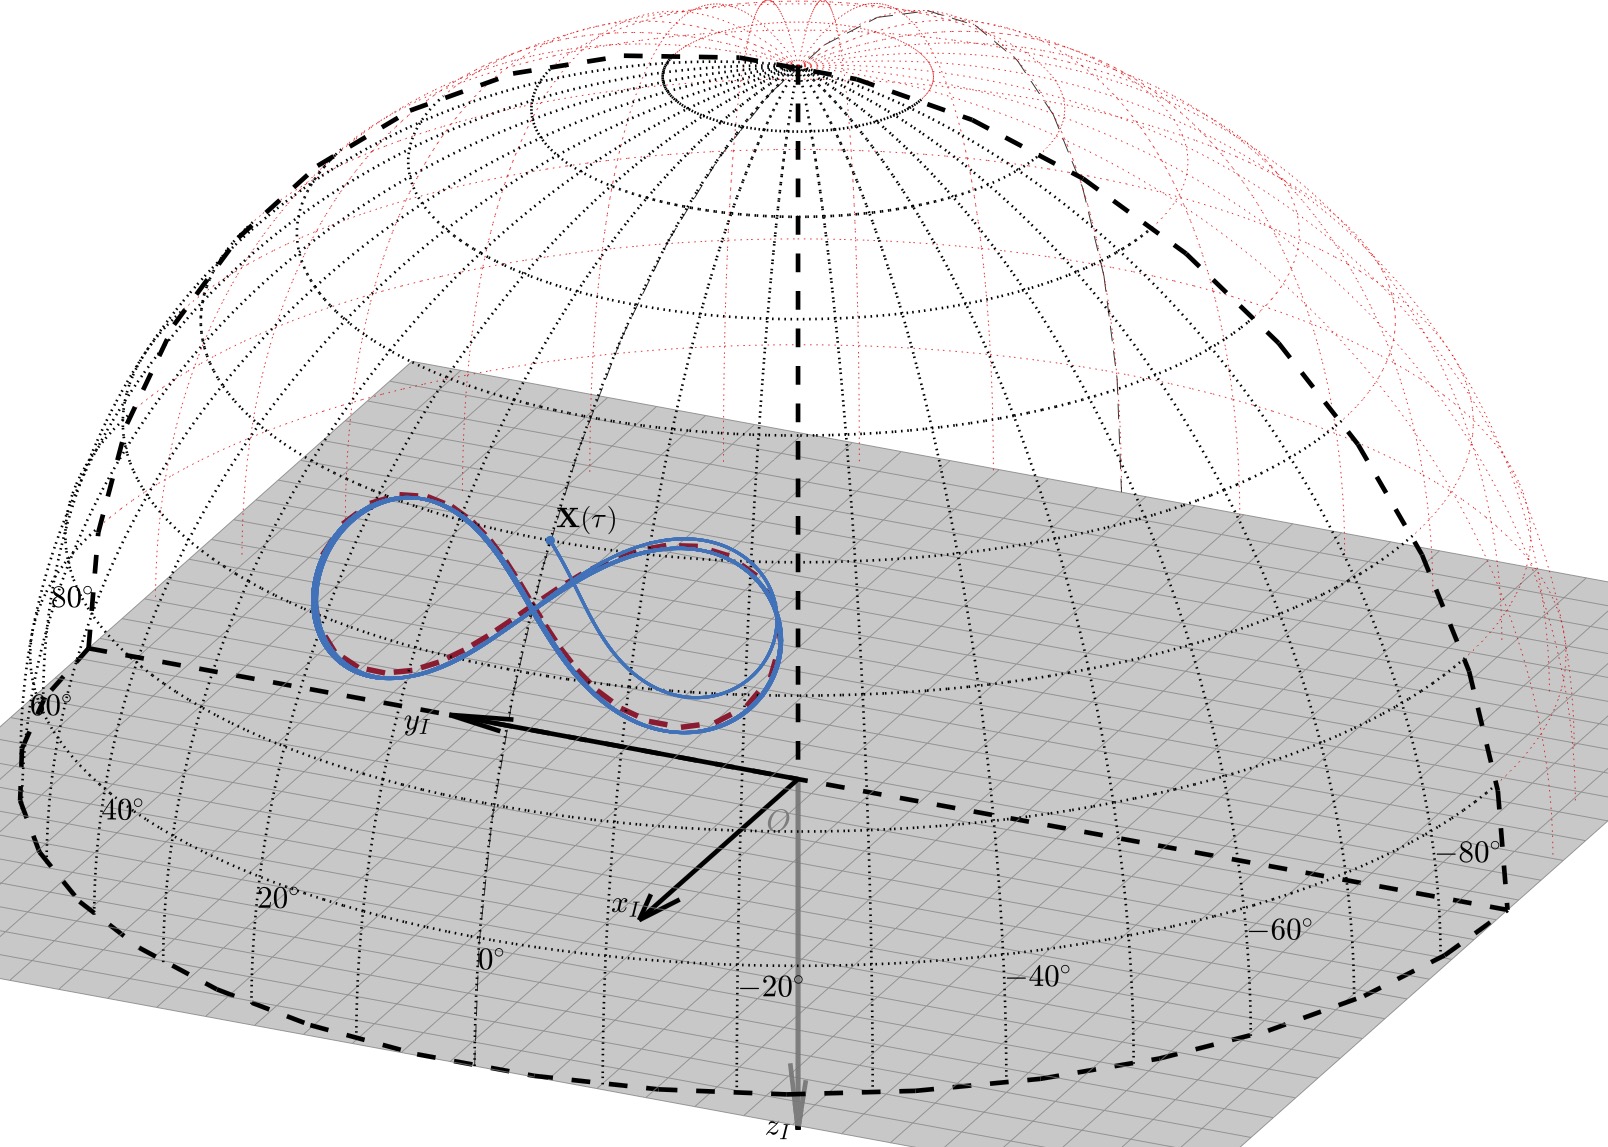
Airborne Wind Energy (AWE) systems based on tethered kites have emerged as a promising solution for ship propulsion and energy generation, with the potential to reduce the associated environmental impact. This work investigates the model-based control of a four-line tethered kite system developed by Beyond the Sea. The control objective is to ensure accurate tracking of a geodesic figure-eight trajectory under varying wind conditions.
News
THESIS DEFENSE of Enso NDREKO - November 10, 2026
Enso NDREKO will defend his thesis on November 10, 2026 at 10:00 am in the amphitheater F of ENSEIRB-MATMECA, on the subject: “Robust Control of a Kite System for Maritime Propulsion: Linear Time-Invariant and Linear Time-Periodic Approaches”.


