THESIS DEFENSE of Simon BERTRAND - October 6, 2026
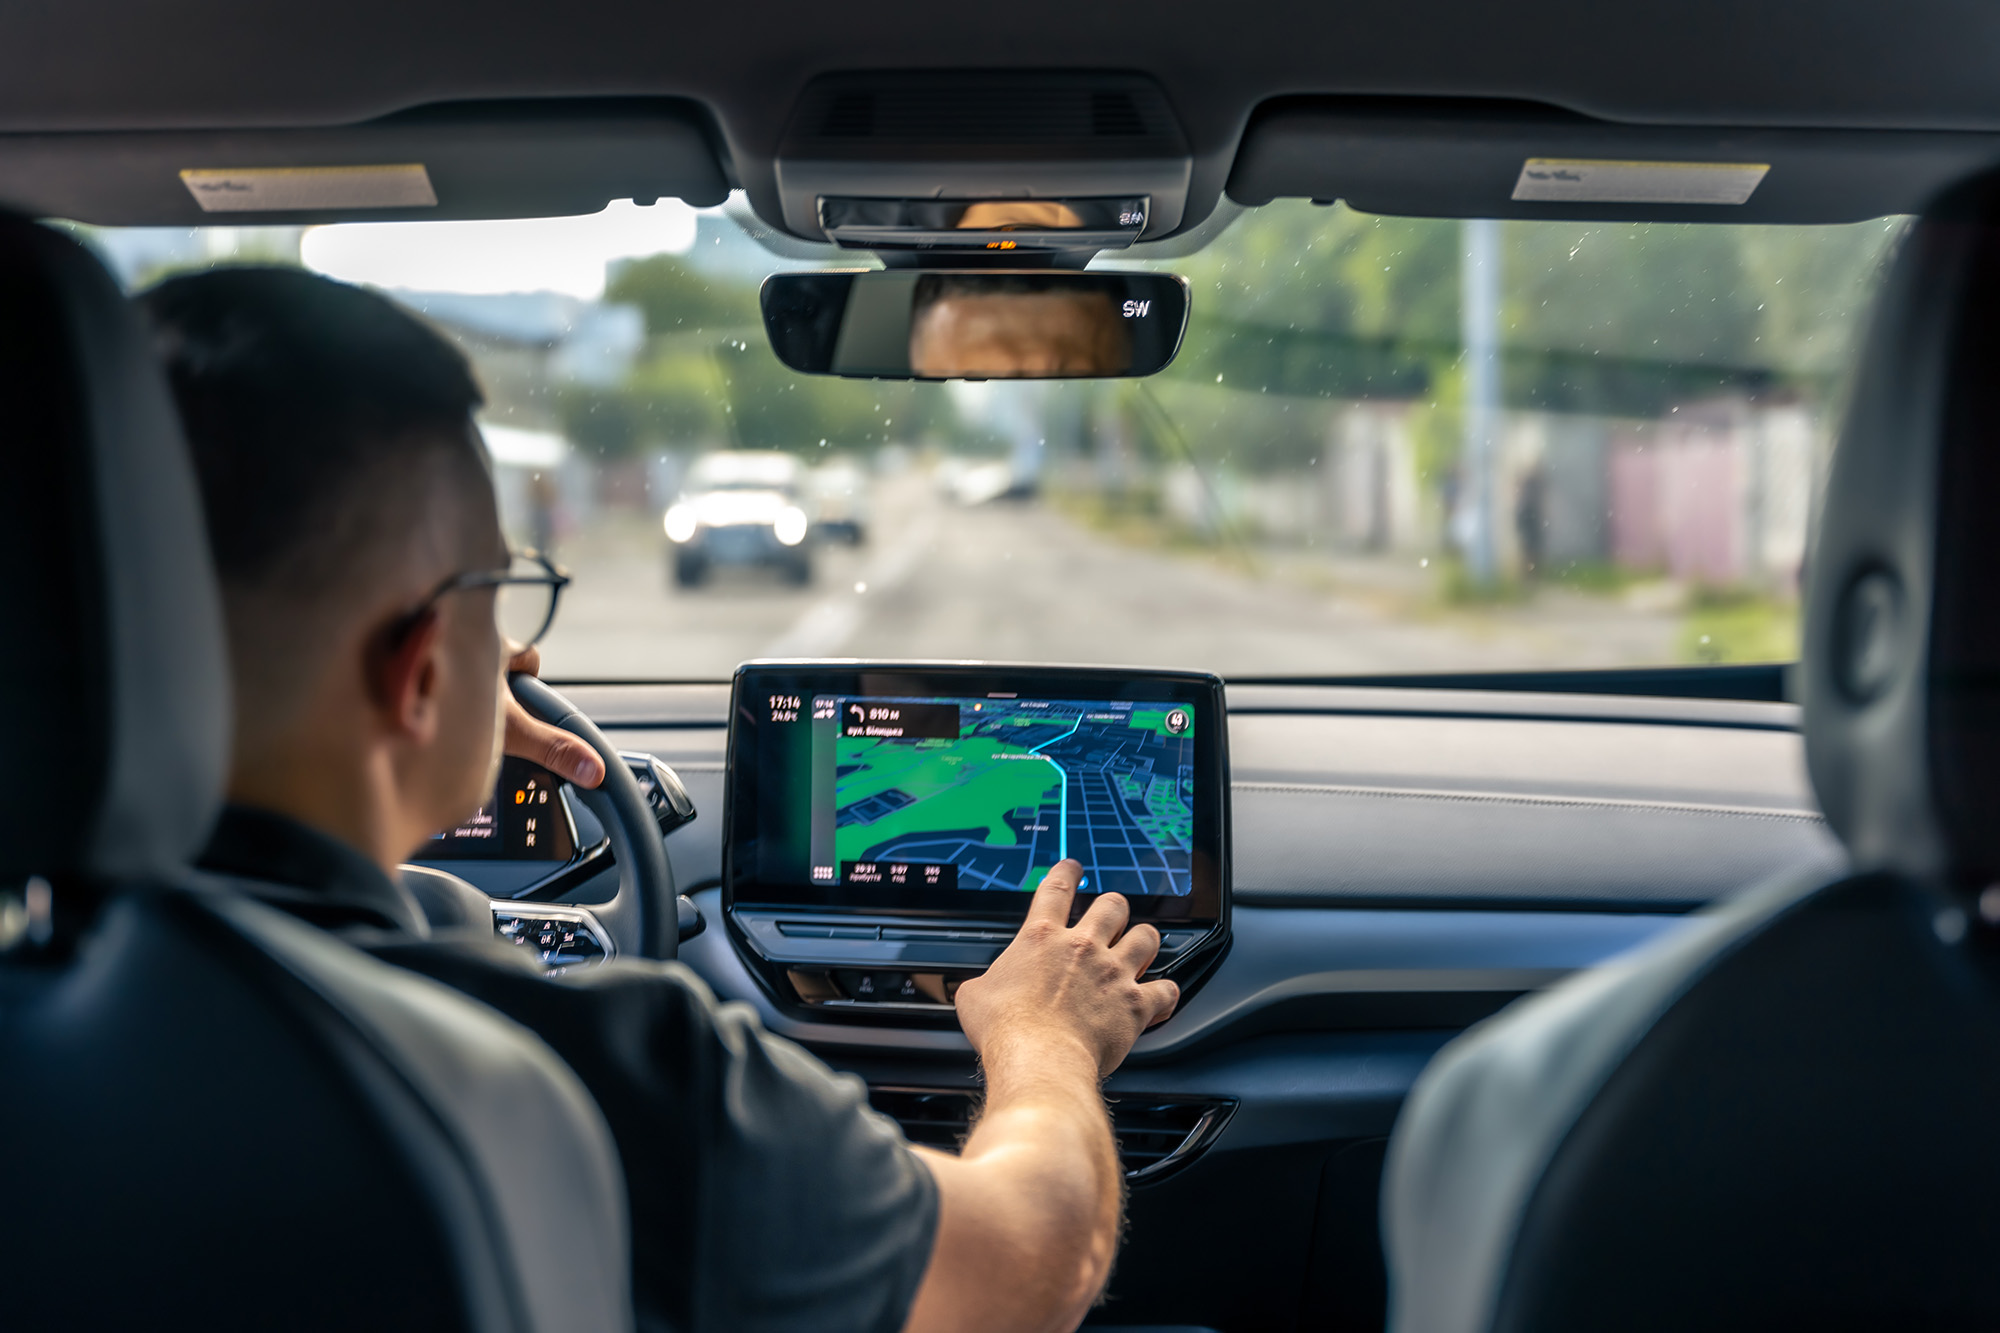
Autonomous navigation systems rely on inertial navigation systems whose errors accumulate over time, leading to drift in the estimated trajectory. In the absence of GPS, terrain-aided navigation provides an alternative for correcting this drift by registering...
THESIS DEFENSE of Vu Hoang Ha PHAM - December 1, 2025
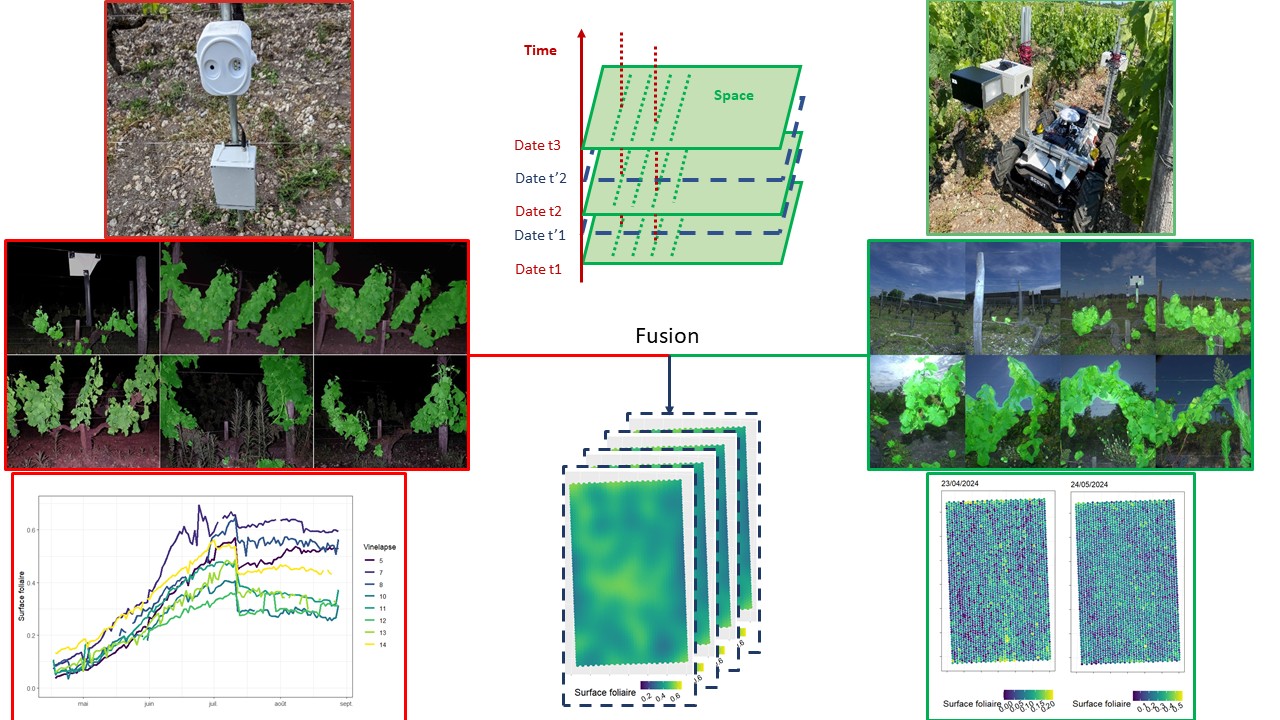
This thesis investigates the spatio-temporal variability of agricultural fields by combining two sources of imaging data: fixed sensors providing temporal series, and mobile sensors delivering spatial maps. The objective is to assess the relevance of...
THESIS DEFENSE of Pedro COUTINHO - November 6, 2025
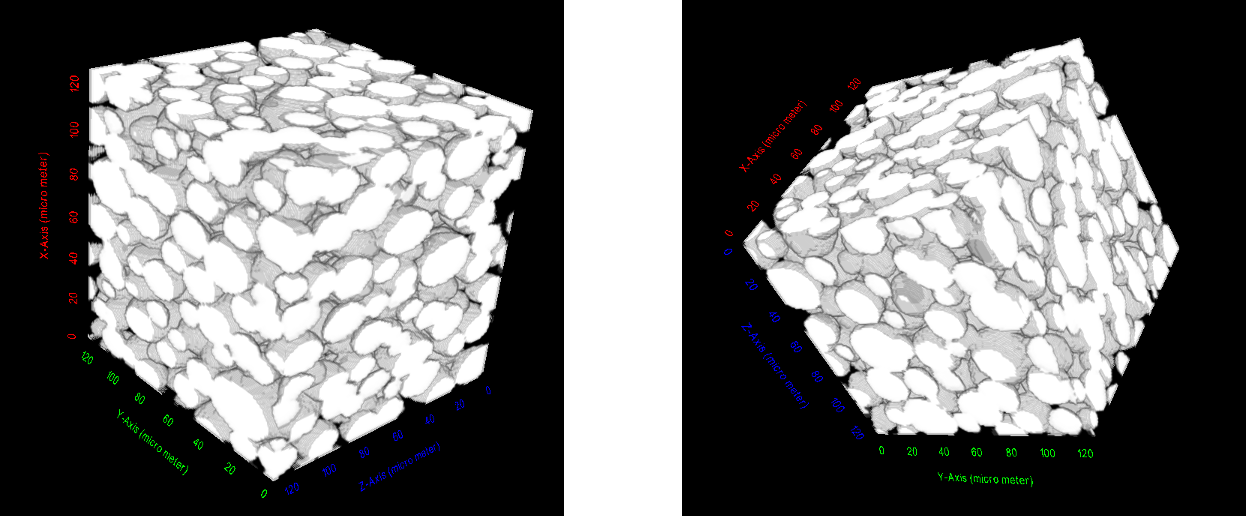
Generative models are powerful methods that allow the synthesis of new data by approximating the probability distribution that describes a dataset. During the past decade, several works have demonstrated their utility to a wide range of applications,...